Notes from the garage.
I work on spacecraft guidance and control for a living. On nights and
weekends I build robots that have to stay upright, and write down how it
is going — what worked, what did not, and the parts I got wrong.
Mike Moore
Aerospace & software engineer · Houston
A single arm on a bench that swings itself up and balances. A brushless
motor, an encoder, and a Rust control loop on a Raspberry Pi at 200 Hz.
It first balanced on 1 September 2026. It now runs five swing-ups a run
under a hardware-in-the-loop regression gate, and the posts are about
the places where the simulator and the bench disagreed.
Overboard
Starting
A self-balancing one-wheel board. The same problem as the pendulum,
except the pendulum is me. Sim-first again, and this time the failure
modes matter rather more. Nothing written yet.
nothing written yet
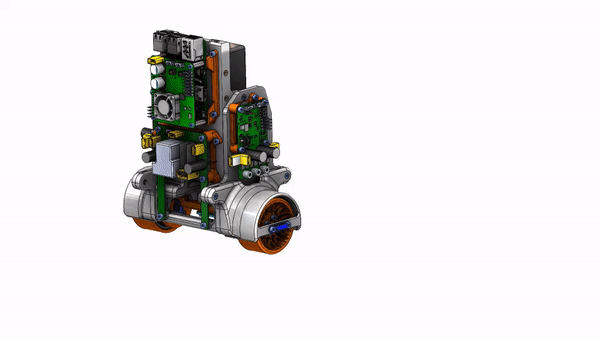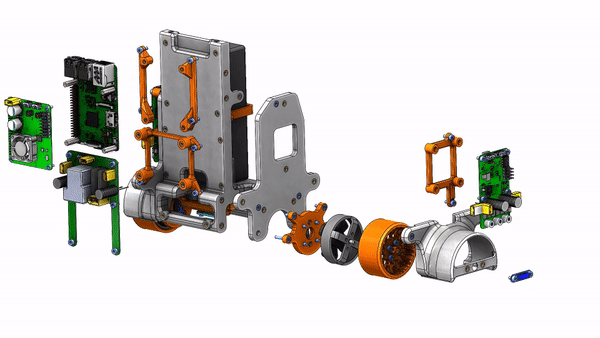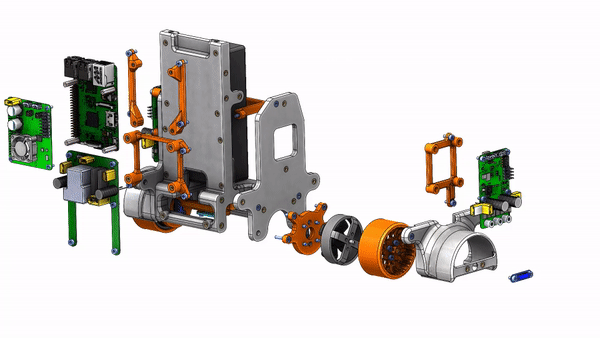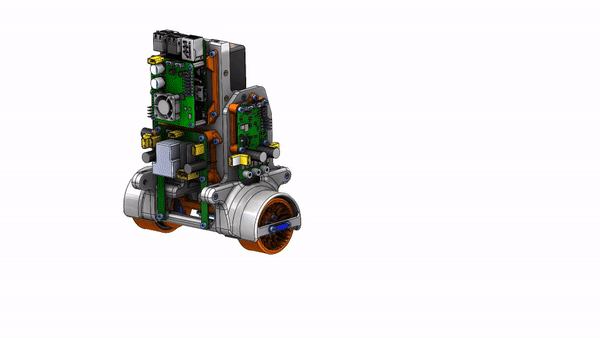
A two-wheeled balancing robot built so students and hobbyists could
play with feedback control on something real. Open source, with a
Gazebo simulation and a real-time controller on a Pi. The clip is the
sim above and the robot below, driving the same square — which is
where the sim-first habit came from.
POS-1
Archive
A quadcopter built from scratch, plus a flight simulator written in
Unity because none of the good open-source ones existed yet.
archive · 2013–14